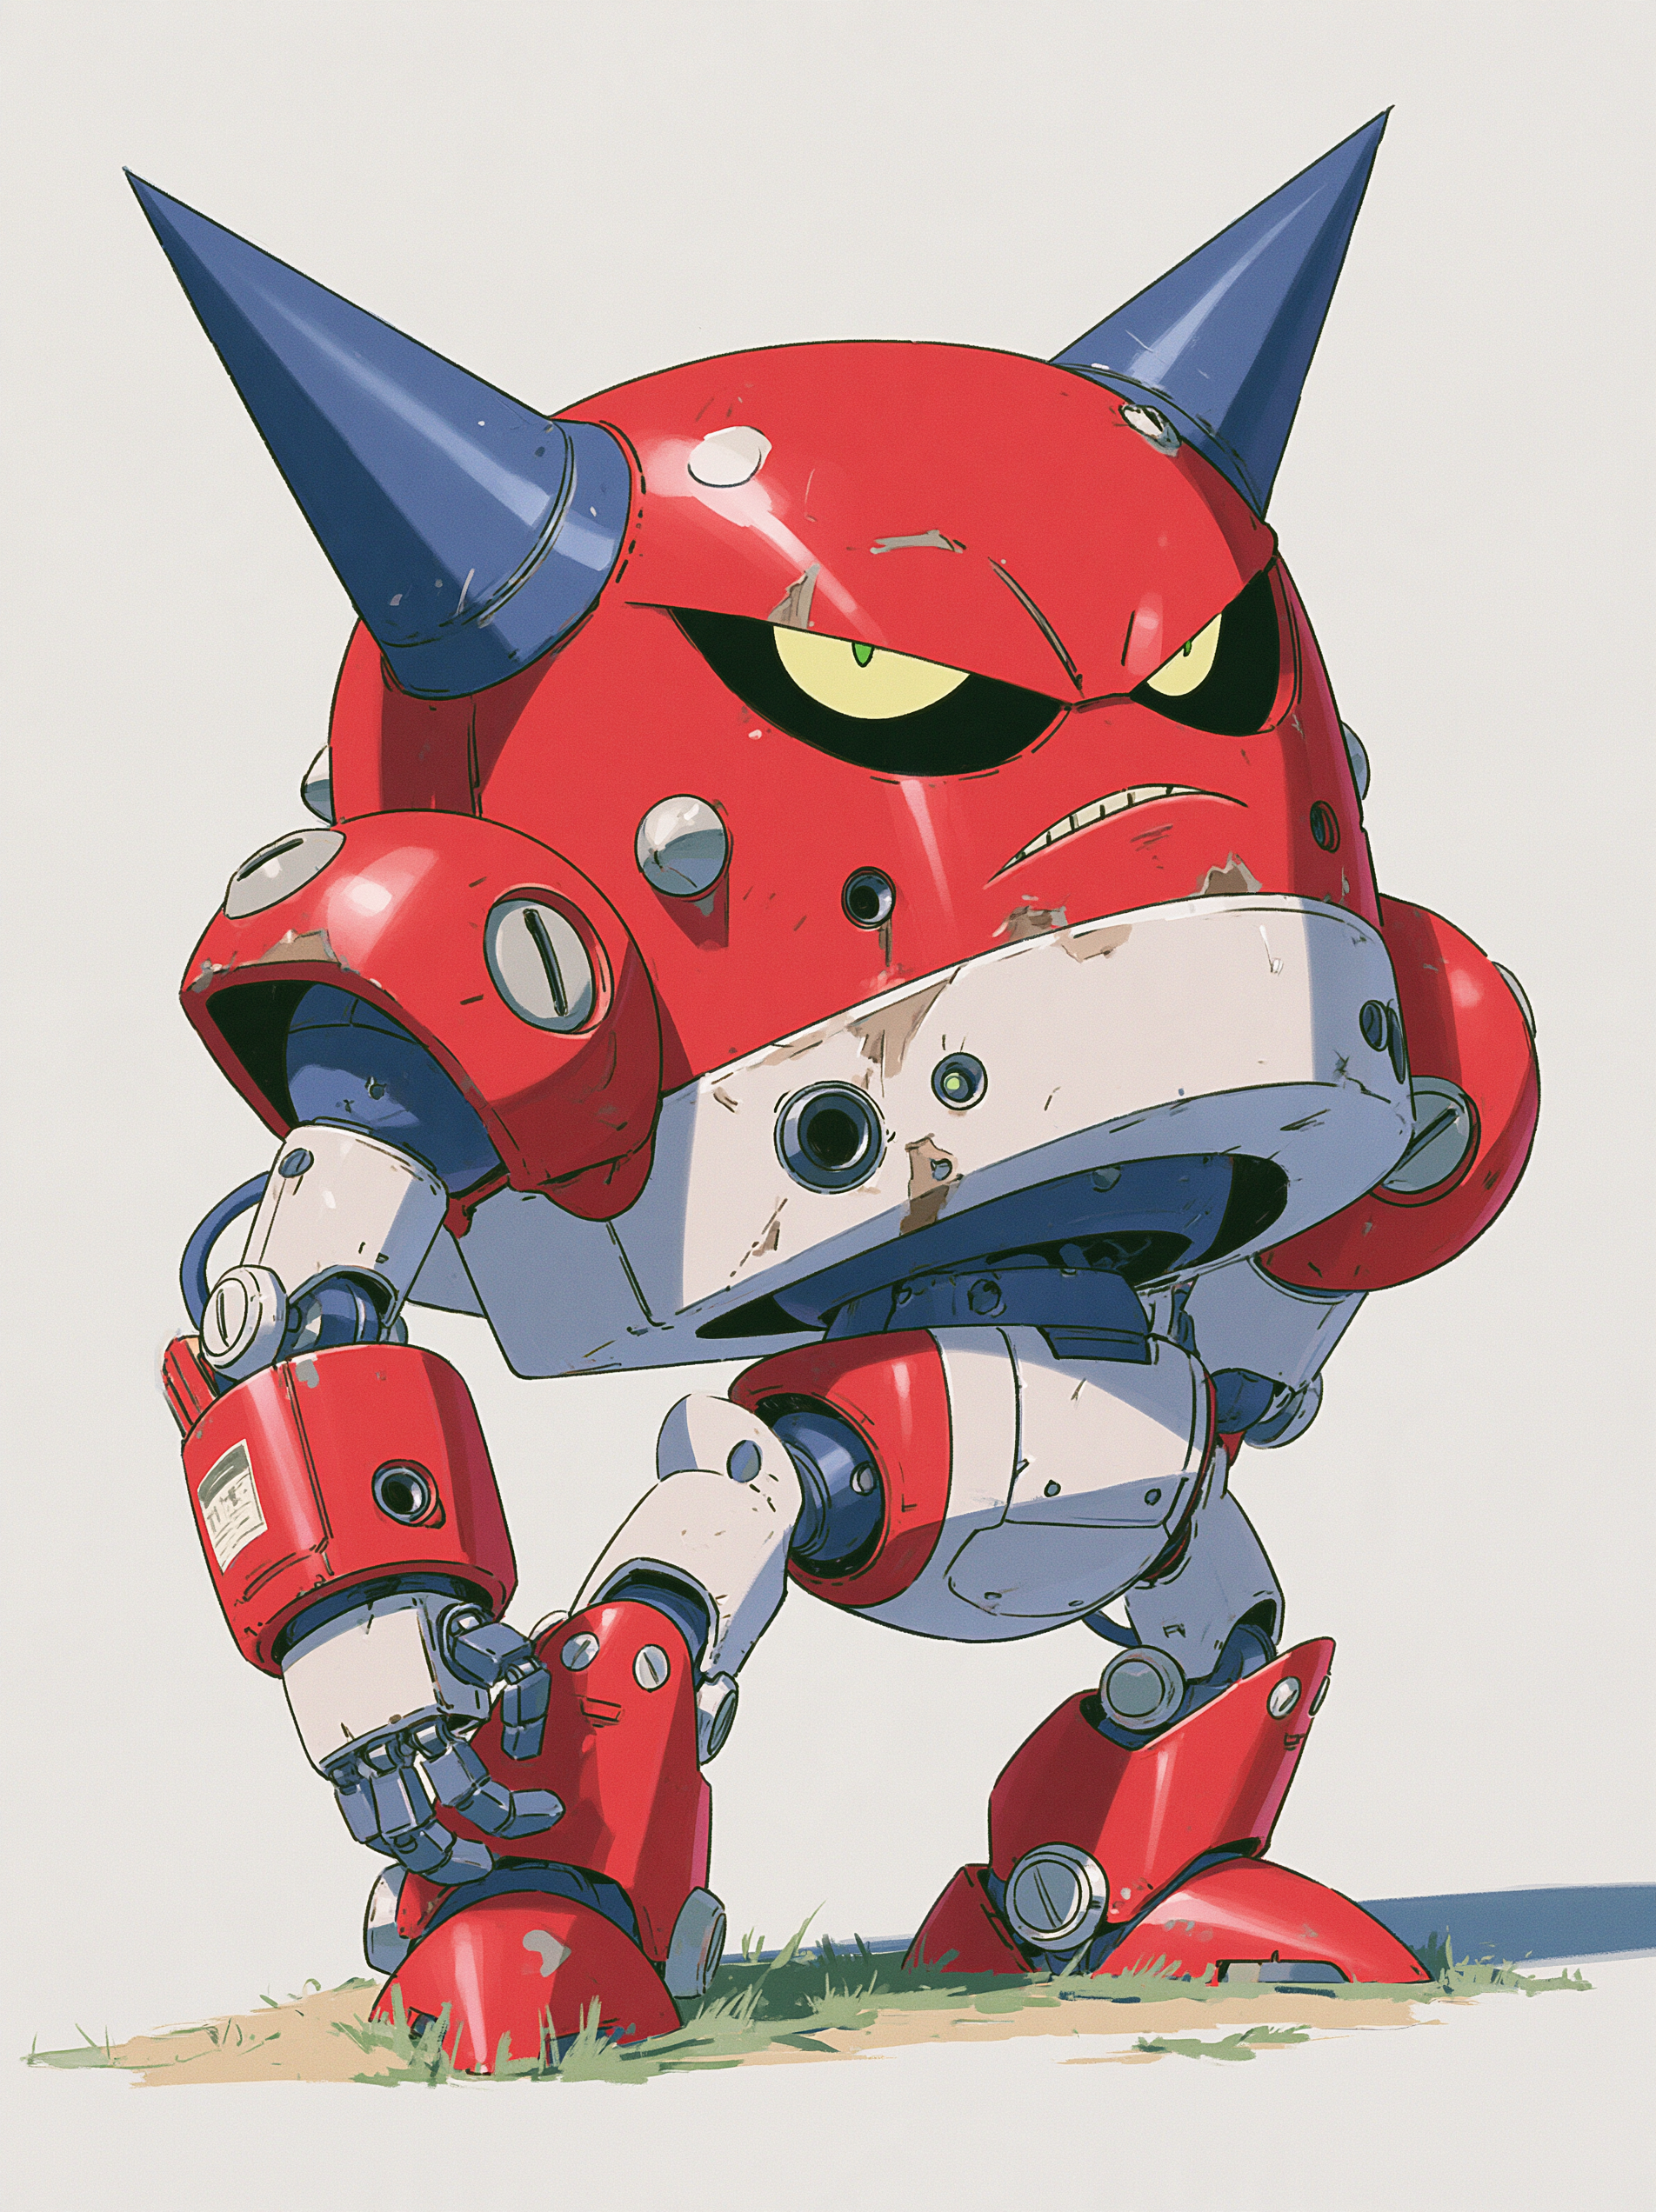
Image 01 · Midjourney 8.2
image prompt
evil robot, simple white background --ar 3:4 --exp 10 --sref 363125409::2 912227515 --profile ukwd6z8 saqoahf --hd --v 8.2
- Model
- Midjourney 8.2
- Format
- 3:4
- Uploaded

Uploaded
Featured film
Step 01 · Image production
Image 01 · Midjourney 8.2
evil robot, simple white background --ar 3:4 --exp 10 --sref 363125409::2 912227515 --profile ukwd6z8 saqoahf --hd --v 8.2
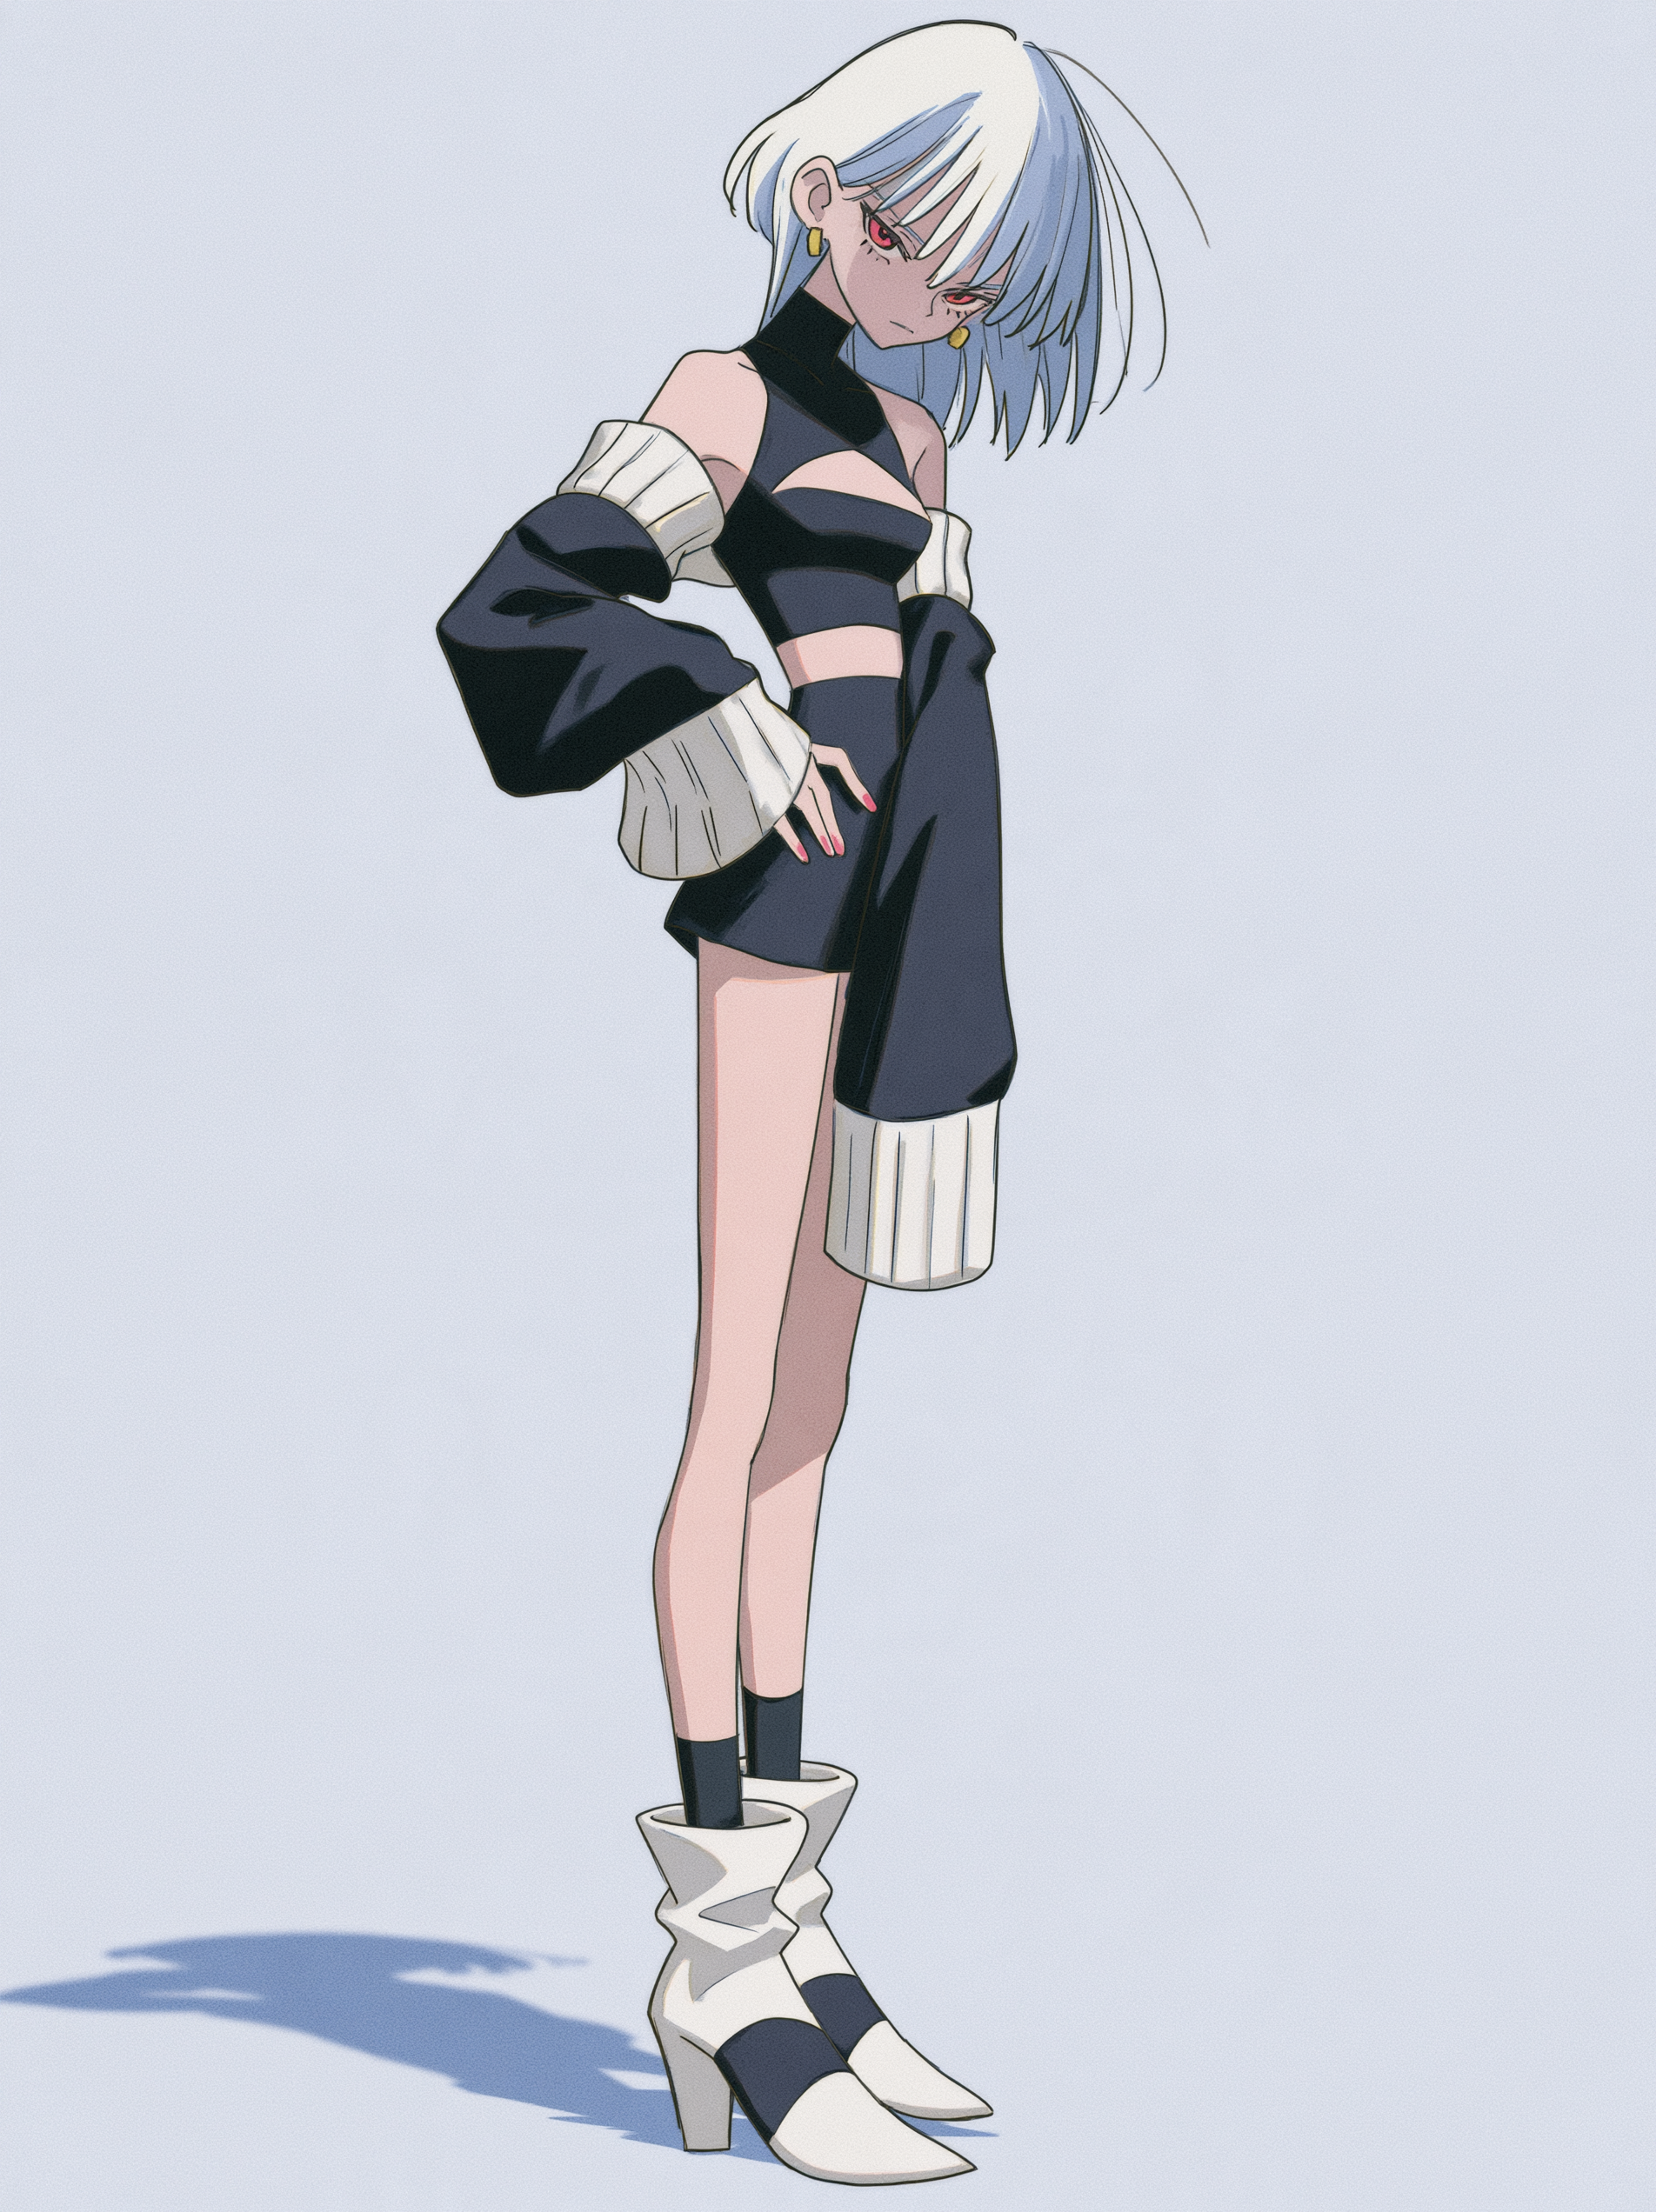
Image 02 · Midjourney 8.2
girl, evil, black & white theme, fullbody character, simple white background --ar 3:4 --exp 10 --sref 363125409::2 912227515 --profile ukwd6z8 saqoahf --hd --v 8.2
Step 02 · Video production
Video 01 · Seedance 2.5
Create a 30-second, 16:9 spectacular hand-drawn anime battle in ten connected shots. A magically enhanced girl fights a giant robot through rapid reciprocal exchanges: parry, sliding evasion, platform vault, forearm run, elbow strike, grab escape, somersault counter, ankle combination, wrist capture, joint lock, and a rotational throw. The robot actively punches, sweeps, grabs, and stomps. Each failed attack creates the next opening. REFERENCES AND WORLD @Image1 defines the girl's exact identity, white bob, red eyes, earrings, black-and-white costume, oversized sleeves, and boots. @Image2 defines the robot's rounded red armor, blue horns, yellow eyes, pale mechanical parts, proportions, and worn paint. Maintain its height at six times hers. Preserve the references' hand-drawn contours, cel shadows, painted texture, and expressive anime proportions. Set the fight in a deserted industrial plaza at sunset: paving slabs, a low concrete loading platform initially behind the girl, distant gantries. Keep landmarks fixed. Start girl left, robot right. Re-establish orientation in a wide view after position changes; show any axis crossing continuously. Cyan-violet runic bands hug her wrists and ankles, amplifying strength, grip, speed, and balance without transforming her body or costume. Trails follow real limbs; shock rings begin at physical contact. No free flight or ranged magic. The robot's right elbow is dented in shot 4, then disabled in shot 8. Carry all damage forward. Its legs remain functional until the throw. Differentiate her fast redirection from its heavy commitments and delayed recovery. SHOT 1 | 0-3s | PARRY INTO A SECOND ATTACK The robot drives a descending right straight toward her. She steps diagonally outside its path, pressing both glowing palms against the passing wrist to divert the fist into paving beside her. She releases once clear. The robot immediately rotates into a left backhand sweep at her height. Reading its loading shoulder, she lowers into a slide beneath the incoming hand. Camera: rapid lateral medium-wide tracking showing her full body and both distinct attack paths. The right punch lands before the left sweep starts. Follow her downward movement; cut as the slide begins. SHOT 2 | 3-6s | SLIDE, PIVOT, EVADE THE STOMP Continue under the left hand with visible clearance. She slides outside its left ankle, plants a palm and then a boot to brake, and rises into a pivot. The robot turns and lifts its left foot to stamp down. She pushes toward the loading platform; the stomp bursts paving behind her trailing boot. End with her reaching the platform and the robot turning toward it. Camera: ground-level side pursuit with fast foreground parallax. Widen after she clears the sweep to include the lifting foot and its impact behind her. Cut on her boot reaching the platform edge. SHOT 3 | 6-9s | RUN UP THE ATTACK She steps fully onto the low platform and loads both knees. The robot punches toward her with its right fist. She springs from the platform just before impact and lands both boots atop the extended forearm near its wrist. The fist smashes the platform below her. Without stopping, she takes two ascending steps along the extended arm toward the elbow. Camera: wide diagonal view establishes the platform, jump, and arm. Crane upward beside her, showing actual boot contacts. Match-cut on the last planted step near the elbow. Effects: glowing foot contacts and concrete spray beneath the fist; gravity stays active. SHOT 4 | 9-12s | ELBOW STRIKE, GRAB RESPONSE From that planted step, she bends and drops her weight into a short left-elbow strike against the robot's right elbow housing. The shell dents and sparks; the arm sags but remains functional. She rebounds into a crouch on the forearm. Its open left hand reaches across to seize her. As the fingers approach, she pushes off the forearm and leaps outward beyond their tips. Camera: rising medium-wide arc keeps her support, strike, and approaching grab together. Brake briefly at the elbow contact, then follow her takeoff. Cut before the fingers finish closing. SHOT 5 | 12-15s | SOMERSAULT THROUGH THE OPENING Continue her outward leap. The fingers close behind her with visible clearance. Brief dramatic slow motion begins at this near miss: she keeps traveling, sleeves stream behind, and eyes track the wrist. She tucks into one backward somersault away from the hand. Snap back to full speed as the fingertips clear. During rotation, extend one boot into the outside of the left wrist, deflecting the missed grab farther aside. Retract, complete the rotation, and land feet-first on clear paving with knees flexed. Camera: wide side follow, a restrained roll matching the rotation; level the horizon before landing. Show the wrist contact and complete landing. Cut on her landing compression. Effects: one ankle trail follows the rotation; a spark marks actual wrist contact. SHOT 6 | 15-18s | DODGE INTO A TWO-HIT COUNTER As she lands, the robot raises its right foot to stomp. She pushes laterally from her landing stance; the foot hits beside her. Its knee flexes. She closes against the planted lower leg: a short right palm-heel strike hits the ankle housing; after the hand recoils, she pivots on her left boot and drives a compact right low kick into the back of that ankle. The foot shifts across fractured paving, forcing a recovery step with its left leg. She retracts the kick and stays outside the right leg. Camera: low three-quarter tracking includes her full body and both robot supports. Follow the dodge, then settle for the two contacts and forced recovery step. SHOT 7 | 18-21s | DUCK AND CAPTURE The robot finishes its recovery step, bends forward, and swings its damaged right arm down across her escape route. She reads the shoulder, ducks beneath the forearm, and steps close to the wrist after the hand passes. Both glowing hands clamp the wrist housing. Her boots plant wide. The remaining momentum drags her briefly through dust, then her enhanced grip arrests it. End with her holding the wrist low, the robot leaning toward her, and its dented elbow exposed. Camera: wide orientation reset, then truck beside the descending arm. Its foreground pass must leave her duck visible. End medium-wide showing her support, captured wrist, and elbow as one connected chain. SHOT 8 | 21-24s | TURN THE CAPTURE INTO A JOINT LOCK Holding the wrist with both hands, she steps around its outside and rotates the forearm against the elbow's natural bend. Her hips turn over a planted foot; her whole body supplies the torque. The dented hinge buckles and sparks, disabling the right arm. She releases as the robot lurches forward to relieve the load. Its intact left hand reaches toward her; she ducks outward and moves to the outside of its right ankle. Camera: fast partial orbit makes the leverage visible without crossing the axis. Stabilize at hinge failure, then widen to show her release and ankle approach. Cut on arrival. Effects: wrist rings tighten, then discharge at the hinge. The disabled arm remains attached and hangs passively. SHOT 9 | 24-27s | ROTATIONAL GIANT THROW The robot is still pitching forward. At its right ankle, she squats and grips the housing with both hands. Driving through both legs, she lifts that foot clear and pulls it across the remaining support. Its torso tips beyond the planted left foot. She pivots hips and shoulders together, hauling the captured ankle through a broad sideways arc. The left foot peels off the ground as balance fails. She releases at the end of her turn, sending the robot into a sideways fall across the open plaza. Use its existing forward momentum; do not pause to lift a stationary robot overhead. Camera: start full-body wide with her squat and both robot feet visible. Crane up and retreat rapidly to reveal the entire falling silhouette. Cut on its downward travel. Effects: ankle runes blaze, paving fractures beneath her support, and a spiral trail follows the actual throwing arc. SHOT 10 | 27-30s | CRASH AND RECOVERY Continue the fall. The robot hits shoulder-and-side first, its disabled right arm folding passively, throwing a broad fan of slabs and dust. She completes her turning follow-through, takes one braking step, and settles into a grounded guard clear of the crash. Her oversized sleeves whip past and settle. In the final second, her inscriptions fade; the robot stays fallen and a loose bolt bounces through the foreground. Camera: wide three-quarter view contains both impact and her recovery. Descend and brake at the crash, then hold the final full-body composition. Dust surrounds rather than conceals the silhouettes. ANIMATION AND EDITING Honor the ten continuous shot ranges. Cuts advance ongoing motion, never repeat attacks. Preserve every handoff: slide to planted rise, platform jump to arm landing, forearm push-off to somersault landing, duck to wrist capture, hinge failure to ankle grip. Keep combinations in wide or medium-wide views. Camera speed comes from foreground passes, elevation changes, parallax, and acceleration; acquire decisive contact before it happens. Use coherent perspective and one dominant camera move per segment. Show anticipation, travel, contact or clearance, recoil, and usable recovery. The opponent reacts and counters instead of waiting. Use explosive drawing spacing, selective limb smears resolving into clean poses, and delayed hair and sleeve follow-through. Slow only the grab near miss. Reserve the largest scale change and impact for the final throw. Energetic orchestral-electronic music with synchronized servos, friction, magical pulses, distinct metal hits, and environmental crashes. No dialogue or subtitles. Avoid repetitive punch-kick loops, phantom hits, teleporting, hovering, repaired damage, extra limbs, costume changes, projectile spells, gore, or a 3D-CGI appearance.